Welcome, I am Wentao Guo. Building embodied intelligence through
data loops and robot hands.
I am a Ph.D. student at The University of Hong Kong, advised by Yanchao Yang, working on Robotics and Embodied AI.
My research aims to build stronger embodied models through data-centric exploration: understanding what data robots need, closing the loop between collection and policy improvement, and developing systems that can continuously refine behavior from real interaction.
I am also interested in hardware as part of the learning pipeline. By designing task-aware robotic hands, grippers, and data-collection devices, I hope to obtain higher-quality interaction data, reshape the action space of manipulation tasks, and study how better hardware design can reduce the burden on robot policies.
News
- 2026.09 TwinRouterBench accepted to NeurIPS 2026 Datasets & Benchmarks Track.
- 2026.09 RoboLineage accepted to CoRL 2026. Congratulations to all co-authors!
- 2026.09 Started my Ph.D. at The University of Hong Kong, advised by Yanchao Yang.
- 2026.06 Won Best Innovation Solution at the 2nd WBCD Competition @ ICRA 2026 with mu0.
- 2026.02 Won Bronze Award at Deep Hackathon 2025.
- 2025.10 Won Best Demo Award at the IROS 2025 Workshop CIM with SCAL.
- 2025.10 Hoecken-D Hand accepted to ROBIO 2025 (Oral).
- 2025.08 Won 1st Place at the ASME Student Mechanism & Robotics Design Competition 2025.
- 2025.07 Hockens-A Hand accepted to IROS 2025 (Oral).
Blog
- Haptic Feedback in Teleoperation: Survey Notes
Survey notes on haptic feedback for teleoperation: how humans perceive touch; vibration, force, electrical stimulation, and fluidic arrays; teleoperation sys...
- Notes on Optimal Transport: From Monge to Sinkhorn
Study notes that go from the Monge problem and the Kantorovich relaxation to entropic regularization and the Sinkhorn algorithm, with a quick look at OT in W...
Publications
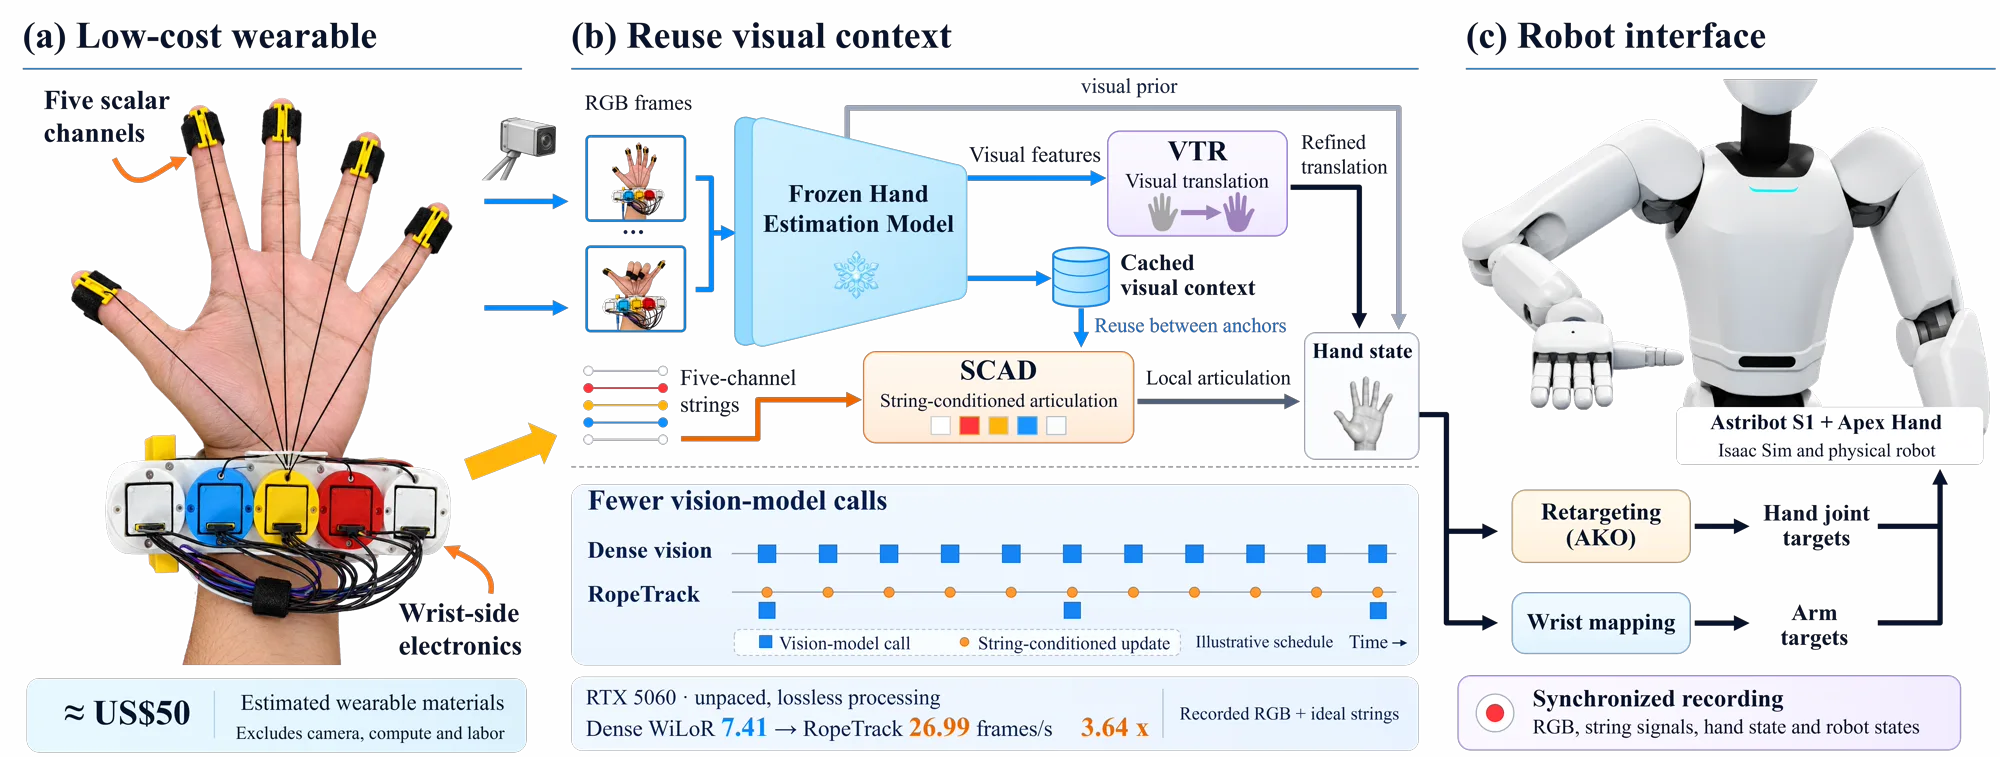
Wentao Guo, Qian Luo, Yu Zhang, Yanchao Yang†.
A low-cost wrist-mounted five-string interface that updates finger articulation between sparse visual reconstructions, for hand pose estimation and robot teleoperation.
Qian Luo, Wentao Guo, Zhennan Qin, Nanchun Guo, Yunhan Zhao, Yi Ma, Yanchao Yang†.
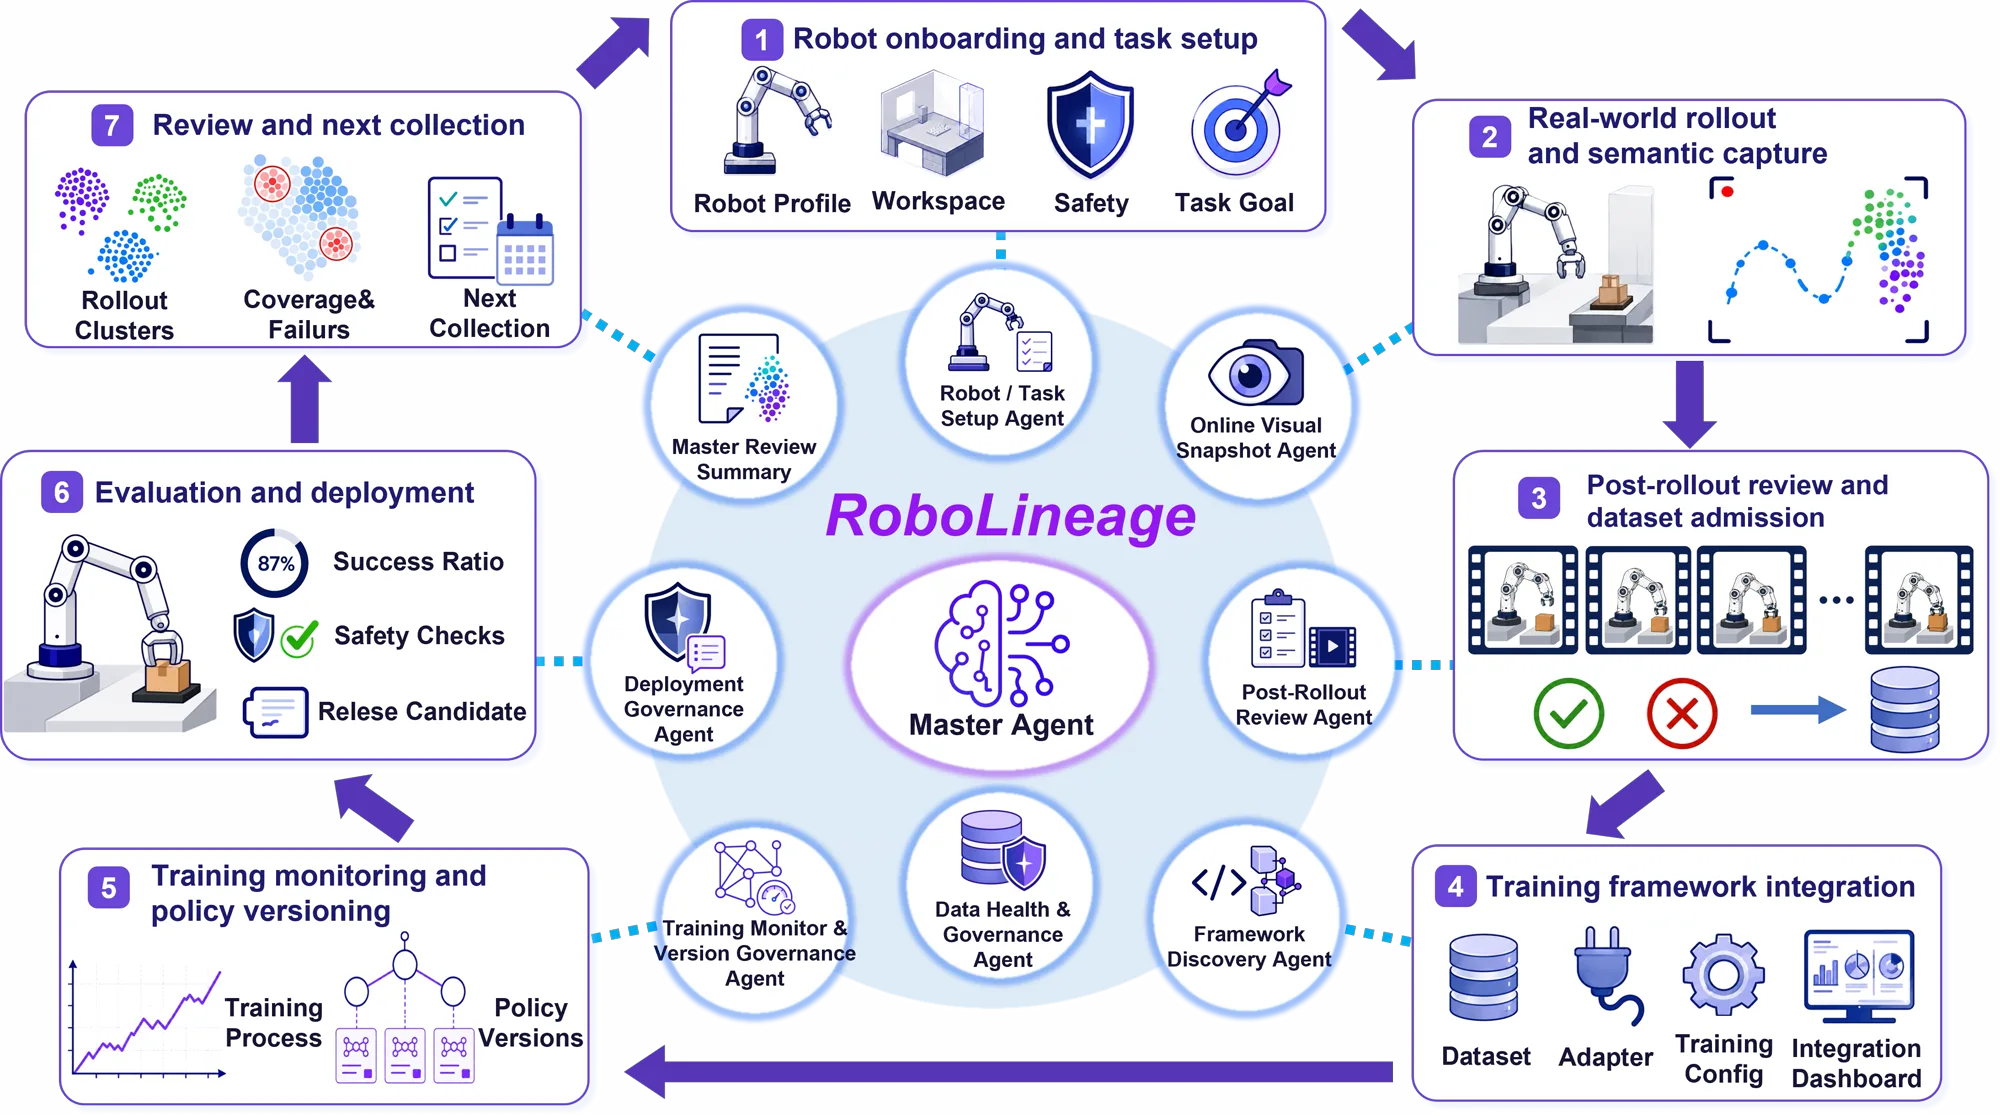
Agent-native lifecycle governance for robot policy iteration across collection, review, training, evaluation, and recollection.
Wentao Guo, Wenzeng Zhang†.
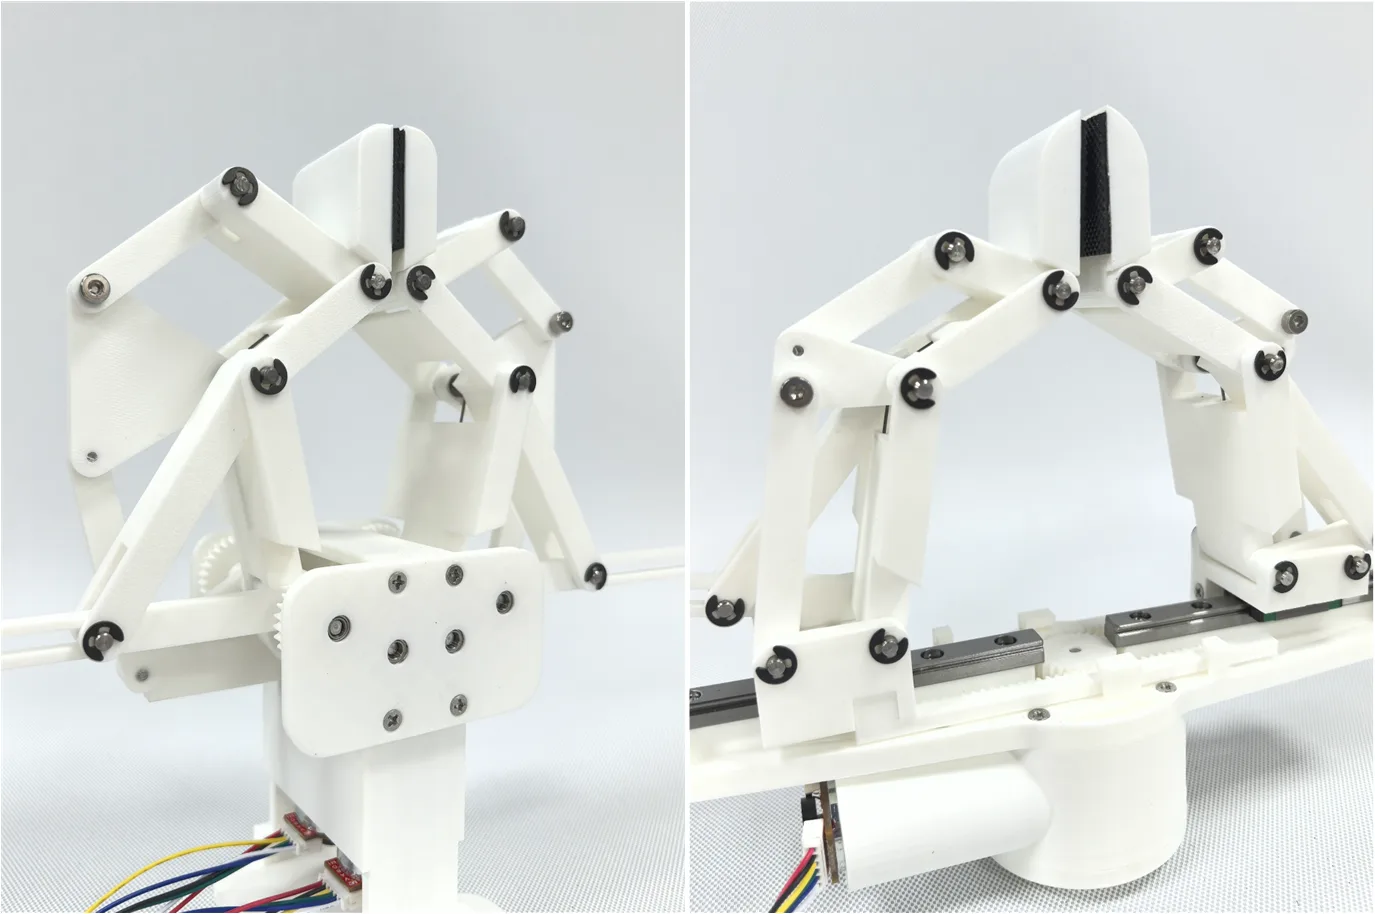
Complementary rotational and linear prototypes for environment-adaptive pinch-lifting and grasping.
Wentao Guo, Wenzeng Zhang†.
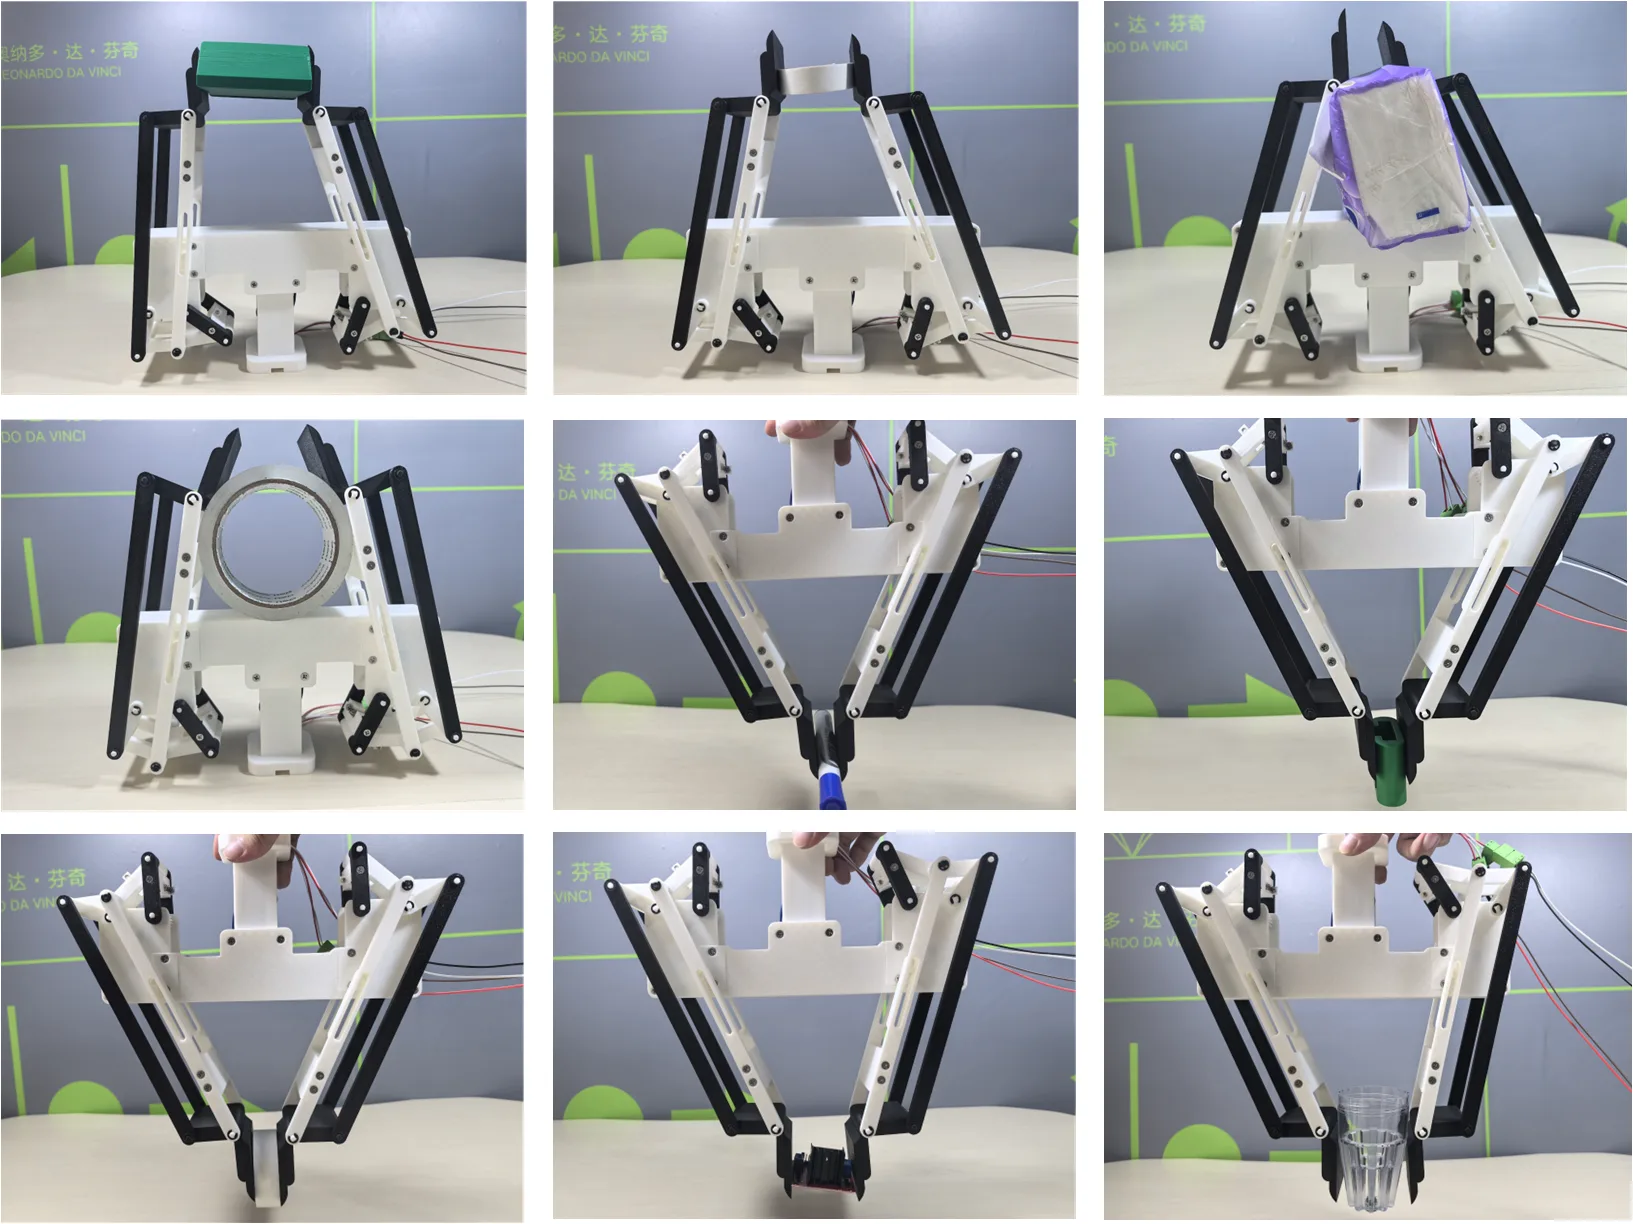
A robotic hand for linear parallel pinching and self-adaptive grasping, designed around compact linkage-driven motion.
Wentao Guo, Yizhou Wang, Wenzeng Zhang†.
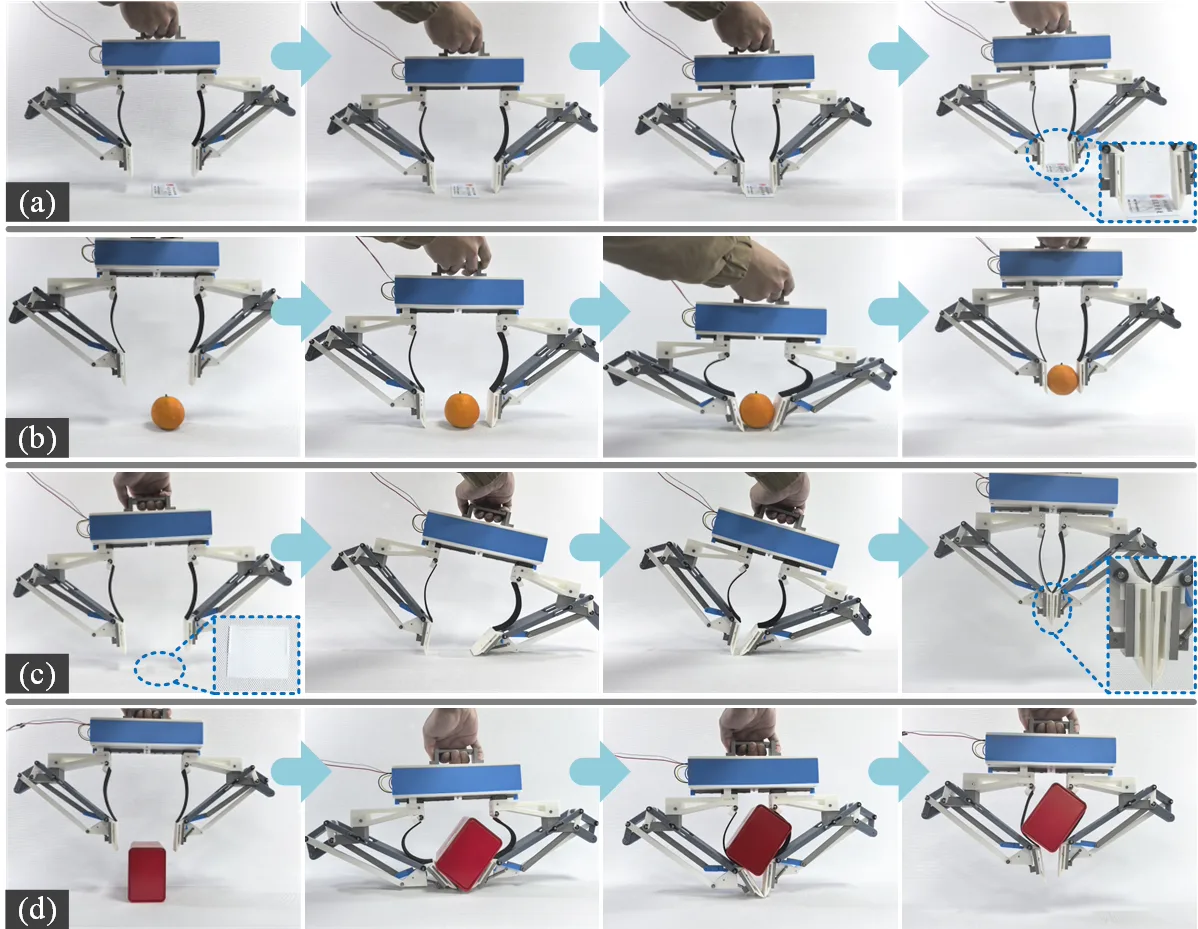
A robot hand design for scooping and self-adaptive grasping in environmental constraints, combining Hoeckens linkages with soft phalanges.
- Under Review RopeTrack: Hand Pose Estimation with Low-Cost String Sensing and Sparse Visual Updates
[video] - CoRL 2026 RoboLineage: Agent-Native Data Lifecycle Governance Across Robot Policy Iterations
[arXiv][page][code][video] - NeurIPS 2026 D&B Track TwinRouterBench: Fast Static and Live Dynamic Evaluation for Realistic Agentic LLM Routing
[arXiv][page][code] - Preprint IROS Workshop CIM Best Demo Award SCAL for Pinch-Lifting: Complementary Rotational and Linear Prototypes for Environment-Adaptive Grasping
[PDF][arXiv][video][poster] - ROBIO 2025 Oral Hoecken-D Hand: A Novel Robotic Hand for Linear Parallel Pinching and Self-Adaptive Grasping
[PDF][arXiv][poster] - IROS 2025 Oral A Novel Robot Hand with Hoeckens Linkages and Soft Phalanges for Scooping and Self-Adaptive Grasping in Environmental Constraints
[PDF][arXiv][video][poster]
Experience
Projects
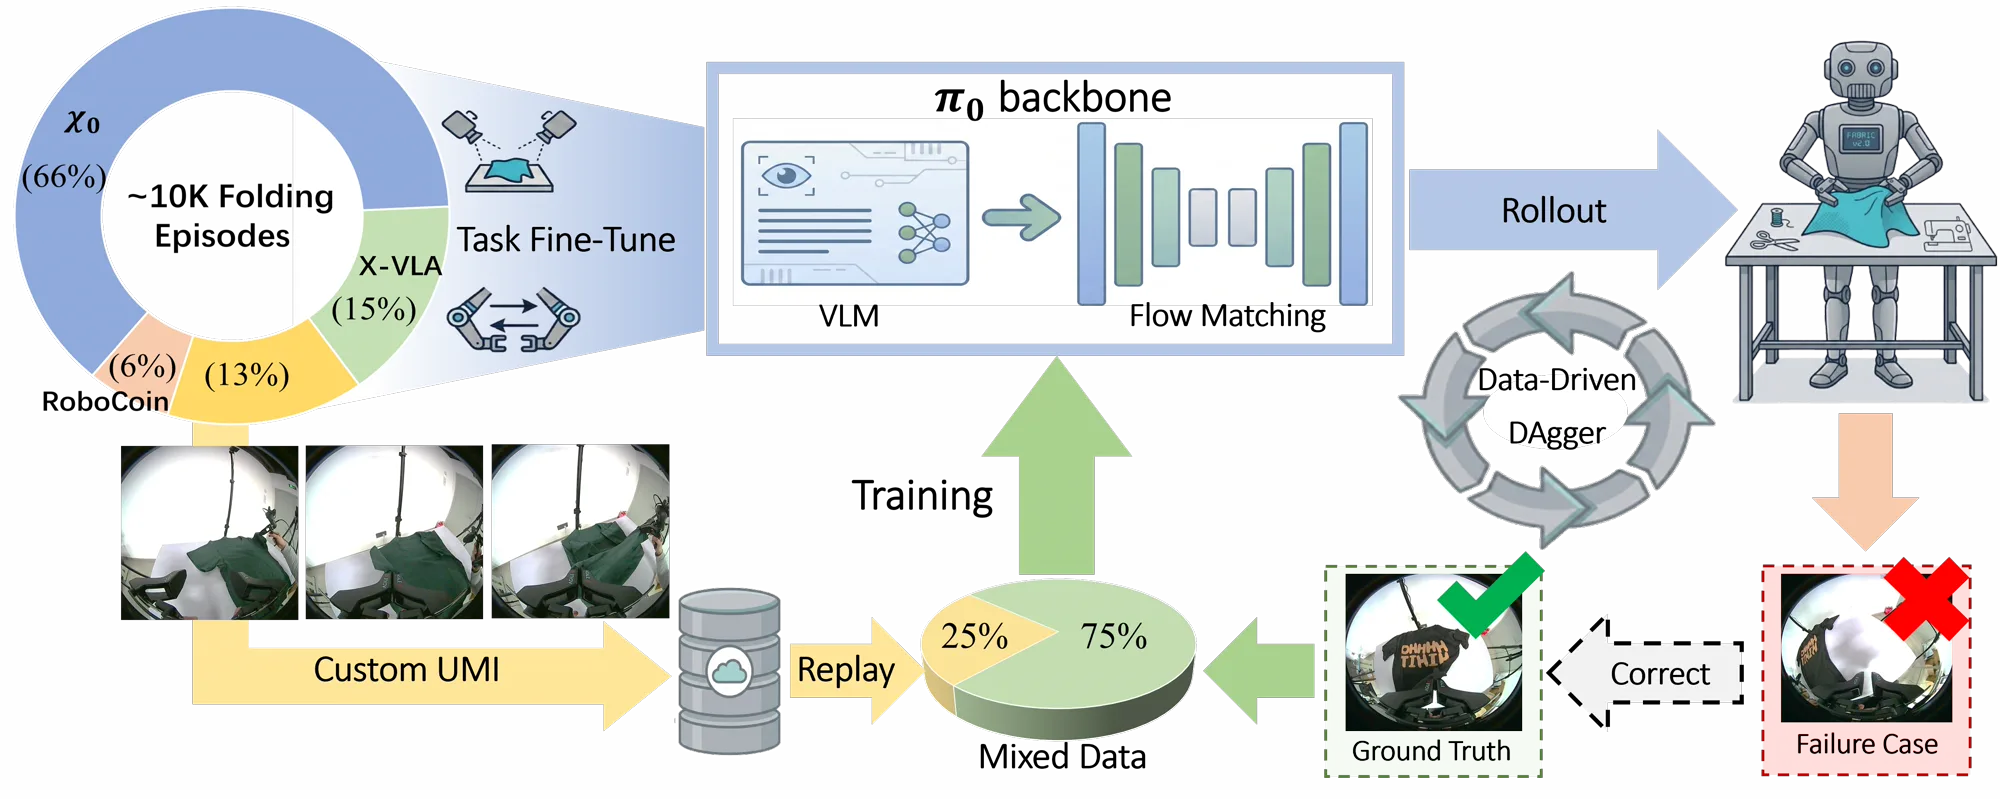
Designed and standardized a task-specific action workflow, collected UMI data, supplemented targeted data with DAgger, and fine-tuned the model for robust deformable-object manipulation.
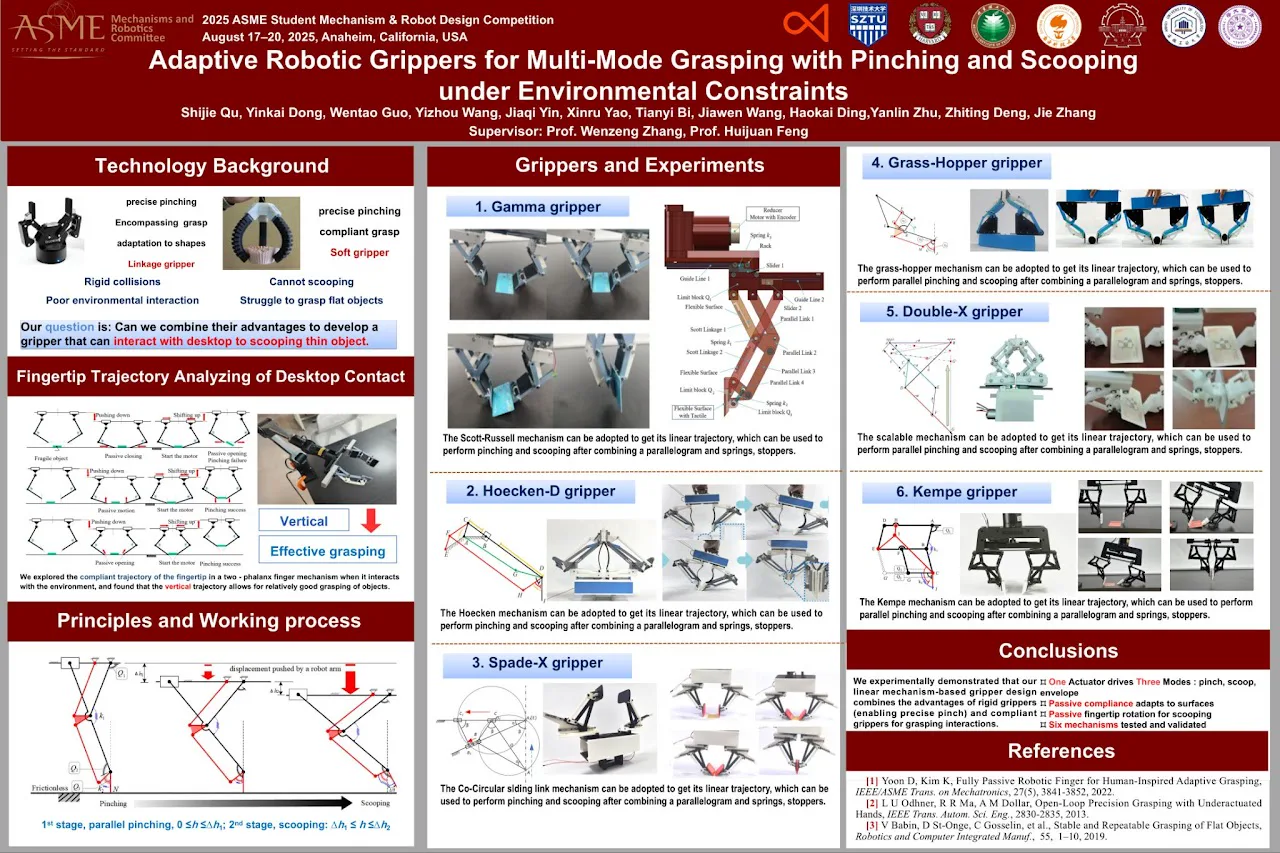
Achieved vertical adaptability via linear linkages, enabling pinch-scoop switching under environmental constraints. Fabricated six 3D-printed prototypes for systematic validation.
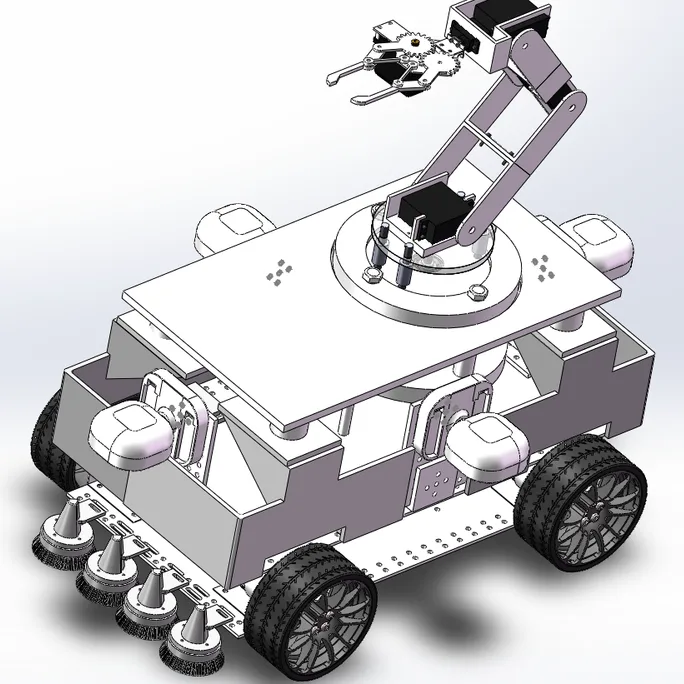
Modular design with navigation, grasping, perception, monitoring, cleaning, and dialogue. Supports modular camera setup with AI recognition. Implemented DQN habit-learning and semi-autonomous execution on Jetson Nano.
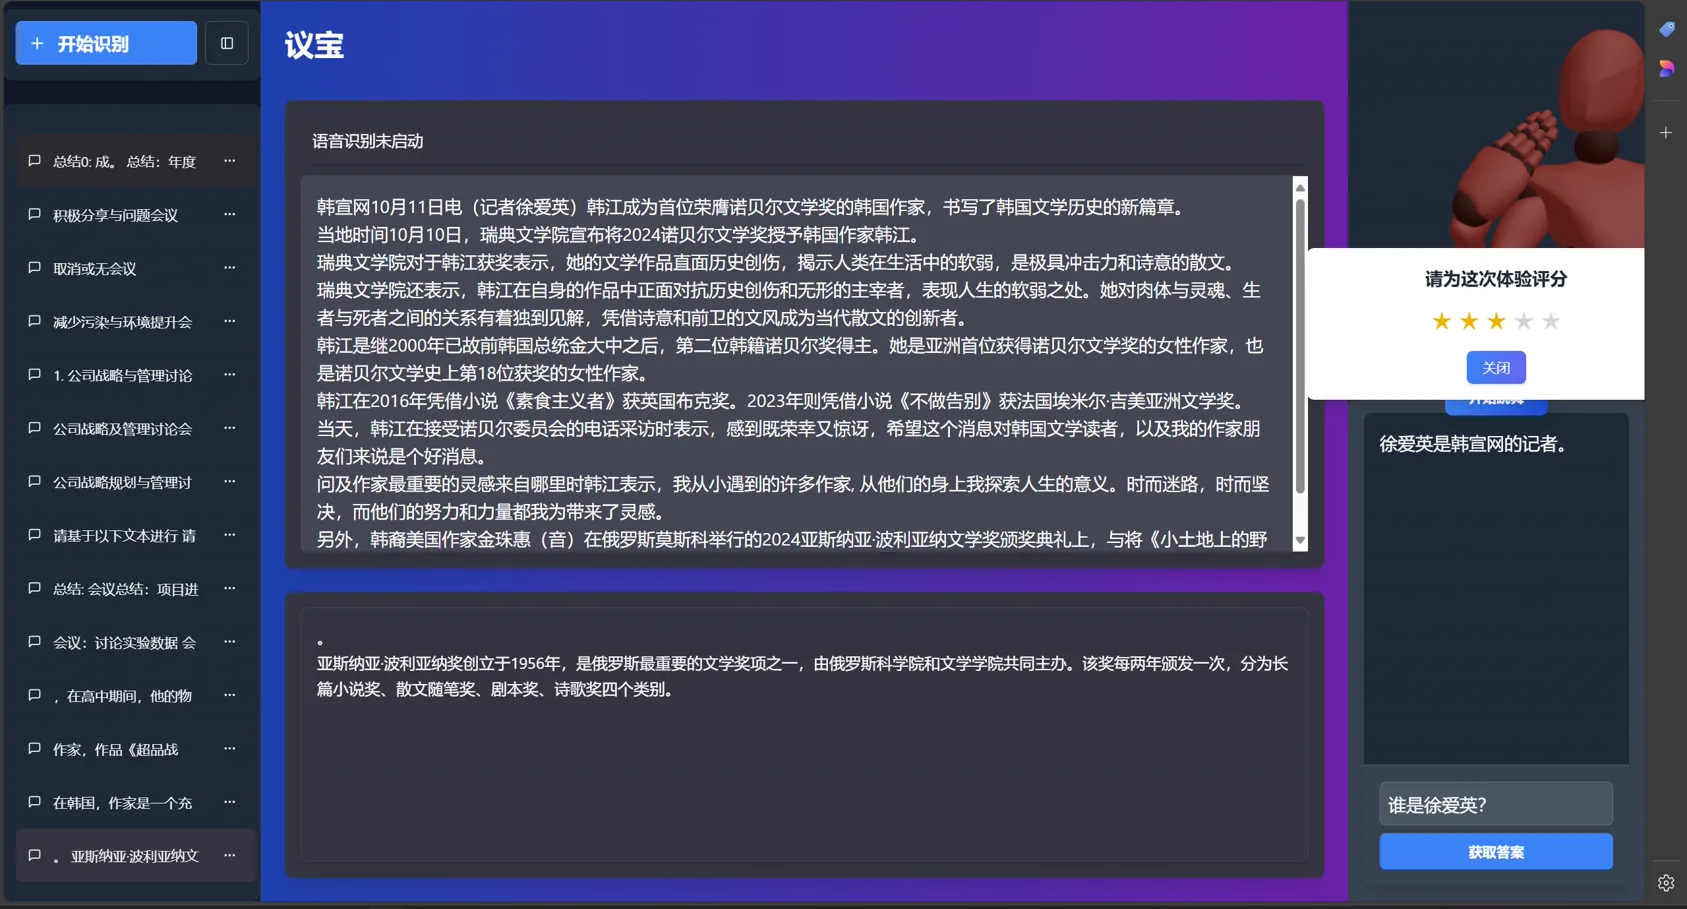
Meeting agent built on Jiuge on-device LLM: integrates local DB, custom summarization, and ASR, with three RAG optimizations (query planning, confidence gating, adversarial robustness) for better minutes and retrieval.
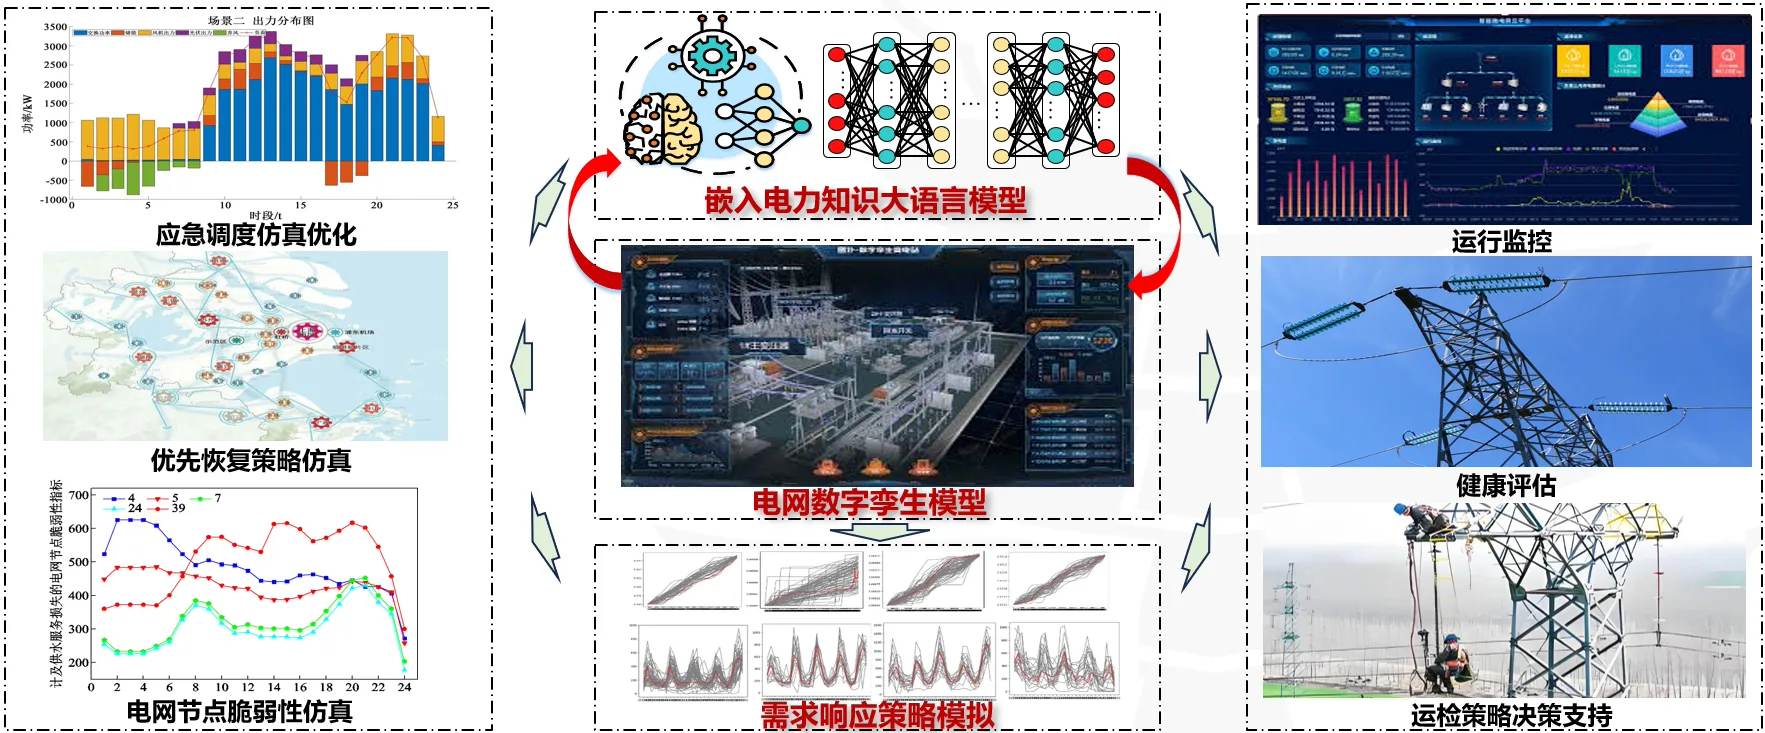
Early warning and recovery for distribution grids under extreme weather: time-series models and a local knowledge base predict vulnerabilities and damage locations, an industry LLM links monitoring to dispatch, and a digital twin supports visualization and strategy simulation.
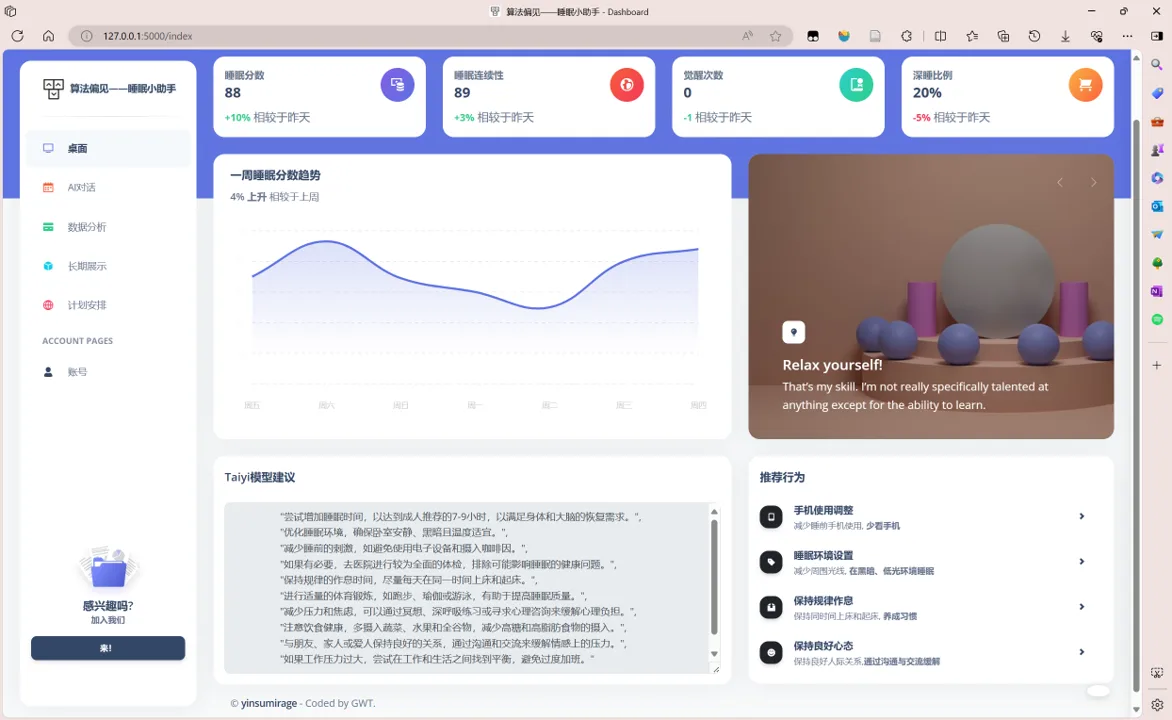
Sleep-focused pipeline: from staging and scoring to LLM analysis and fine-tuning. Applied fine-tuning and constraints to reduce bias, with clustering-based updates planned for continuous improvement.
Awards & Honors
2026
- Best Innovation Solution, 2nd WBCD Competition @ ICRA 2026 International
- Bronze Award, Deep Hackathon 2025 National
2025
- Best Demo Award, IROS 2025 Workshop CIM International
- 1st Place, ASME Student Mechanism & Robotics Design Competition International
- Meritorious Winner, Mathematical Contest in Modeling (MCM/ICM) International
2024
- 1st Prize, RoboCup Innovation ('Robot+' Finals) National
- 1st Prize, China University Intelligent Robot Creative Competition (7th) National
- 2nd Prize, China Intelligent Robot Combat & Competition (Vision-based Antagonism) National
- 2nd Prize, International Youth AI Competition (6th) National
- Special Prize, Challenge Cup - Problem-Driven Special Track (Jiebang Gua Shuai) National
- 3rd Prize, Open-Source Innovation Competition National
- Disruptive Innovation Award, X-Camp · X-Challenge Track 7 National